Figure-led tutorial · group meetingFigure-led tutorial · group meeting
单观测 Pareto GTI:
线约束与连续谱不变量Single-observation Pareto GTI:
line constraint and continuum invariant
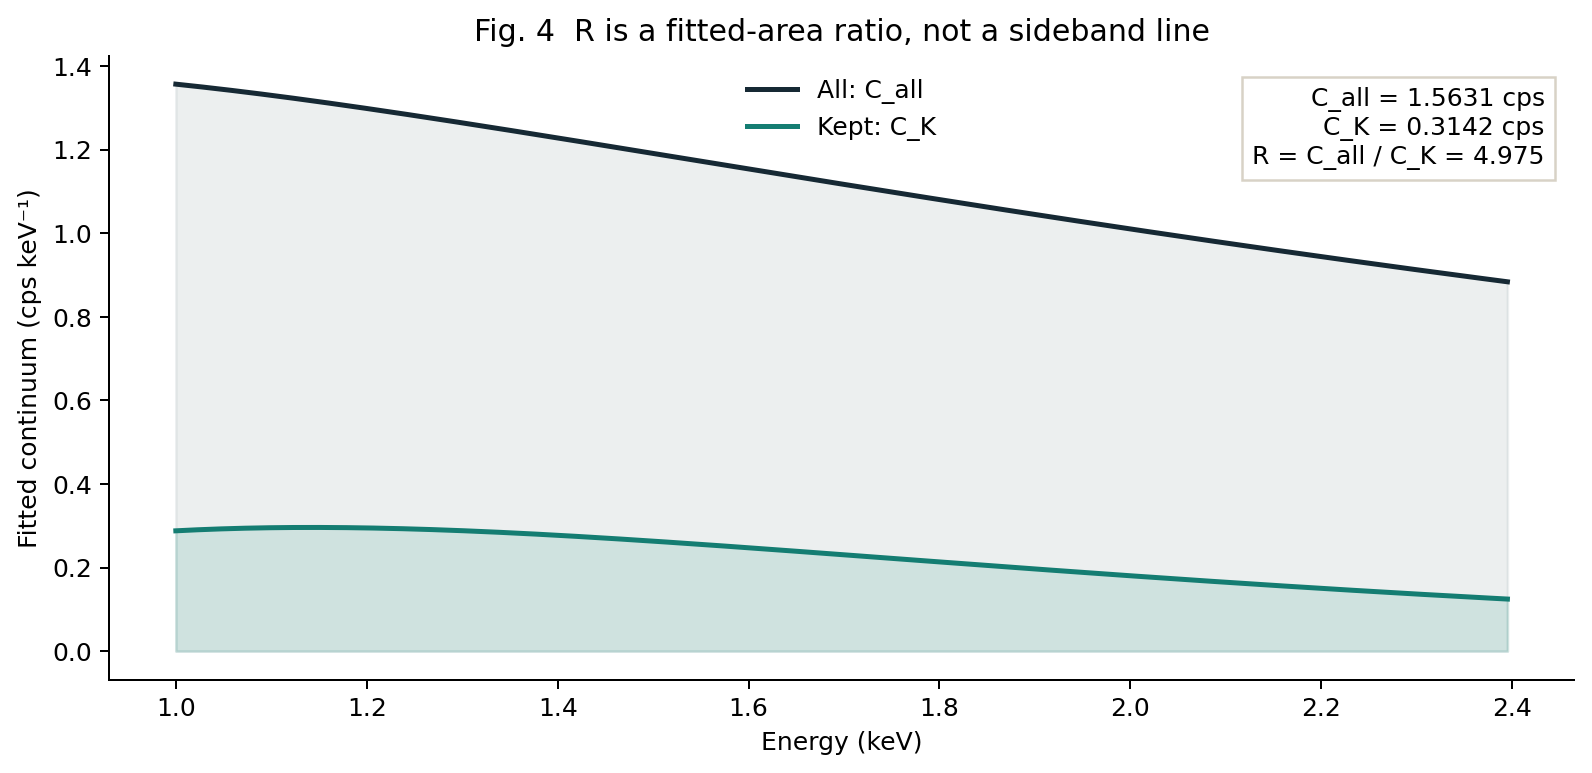
一句话:对一个观测,在约束 \(L_\mathrm{all}=L_K\) 下,寻找保留活时间 \(T_K\) 与连续谱降低倍数 \(R=C_\mathrm{all}/C_K\) 的 Pareto 前沿。In one sentence: for one observation, find the Pareto frontier of retained live time \(T_K\) and continuum reduction \(R=C_\mathrm{all}/C_K\) subject to \(L_\mathrm{all}=L_K\).
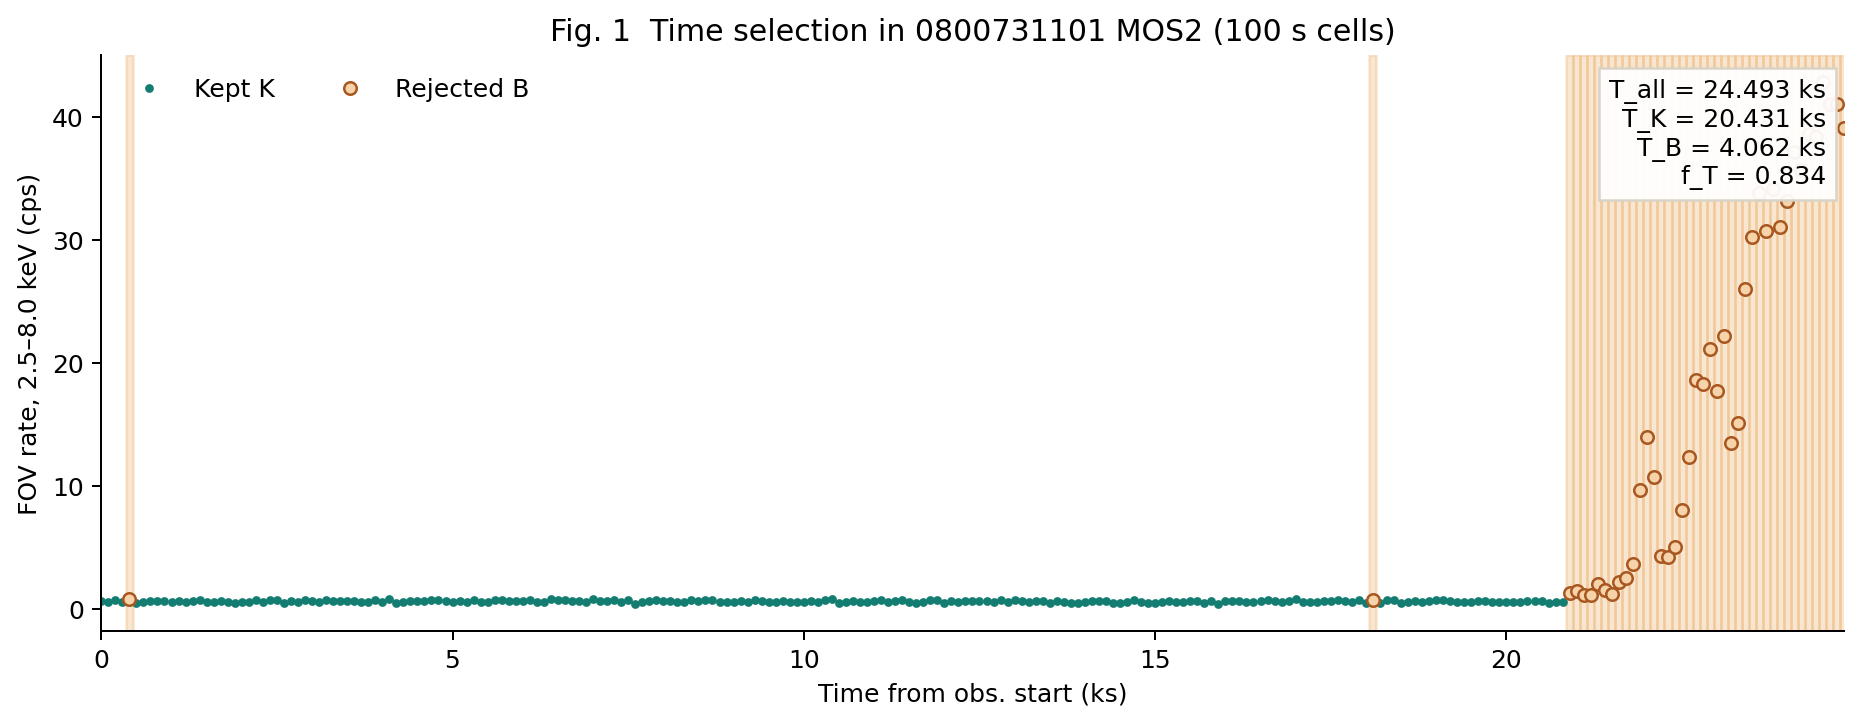
视场 FOV light curve 构造 GTI;CORNER 只作诊断。The FOV light curve constructs the GTI; CORNER is diagnostic only.
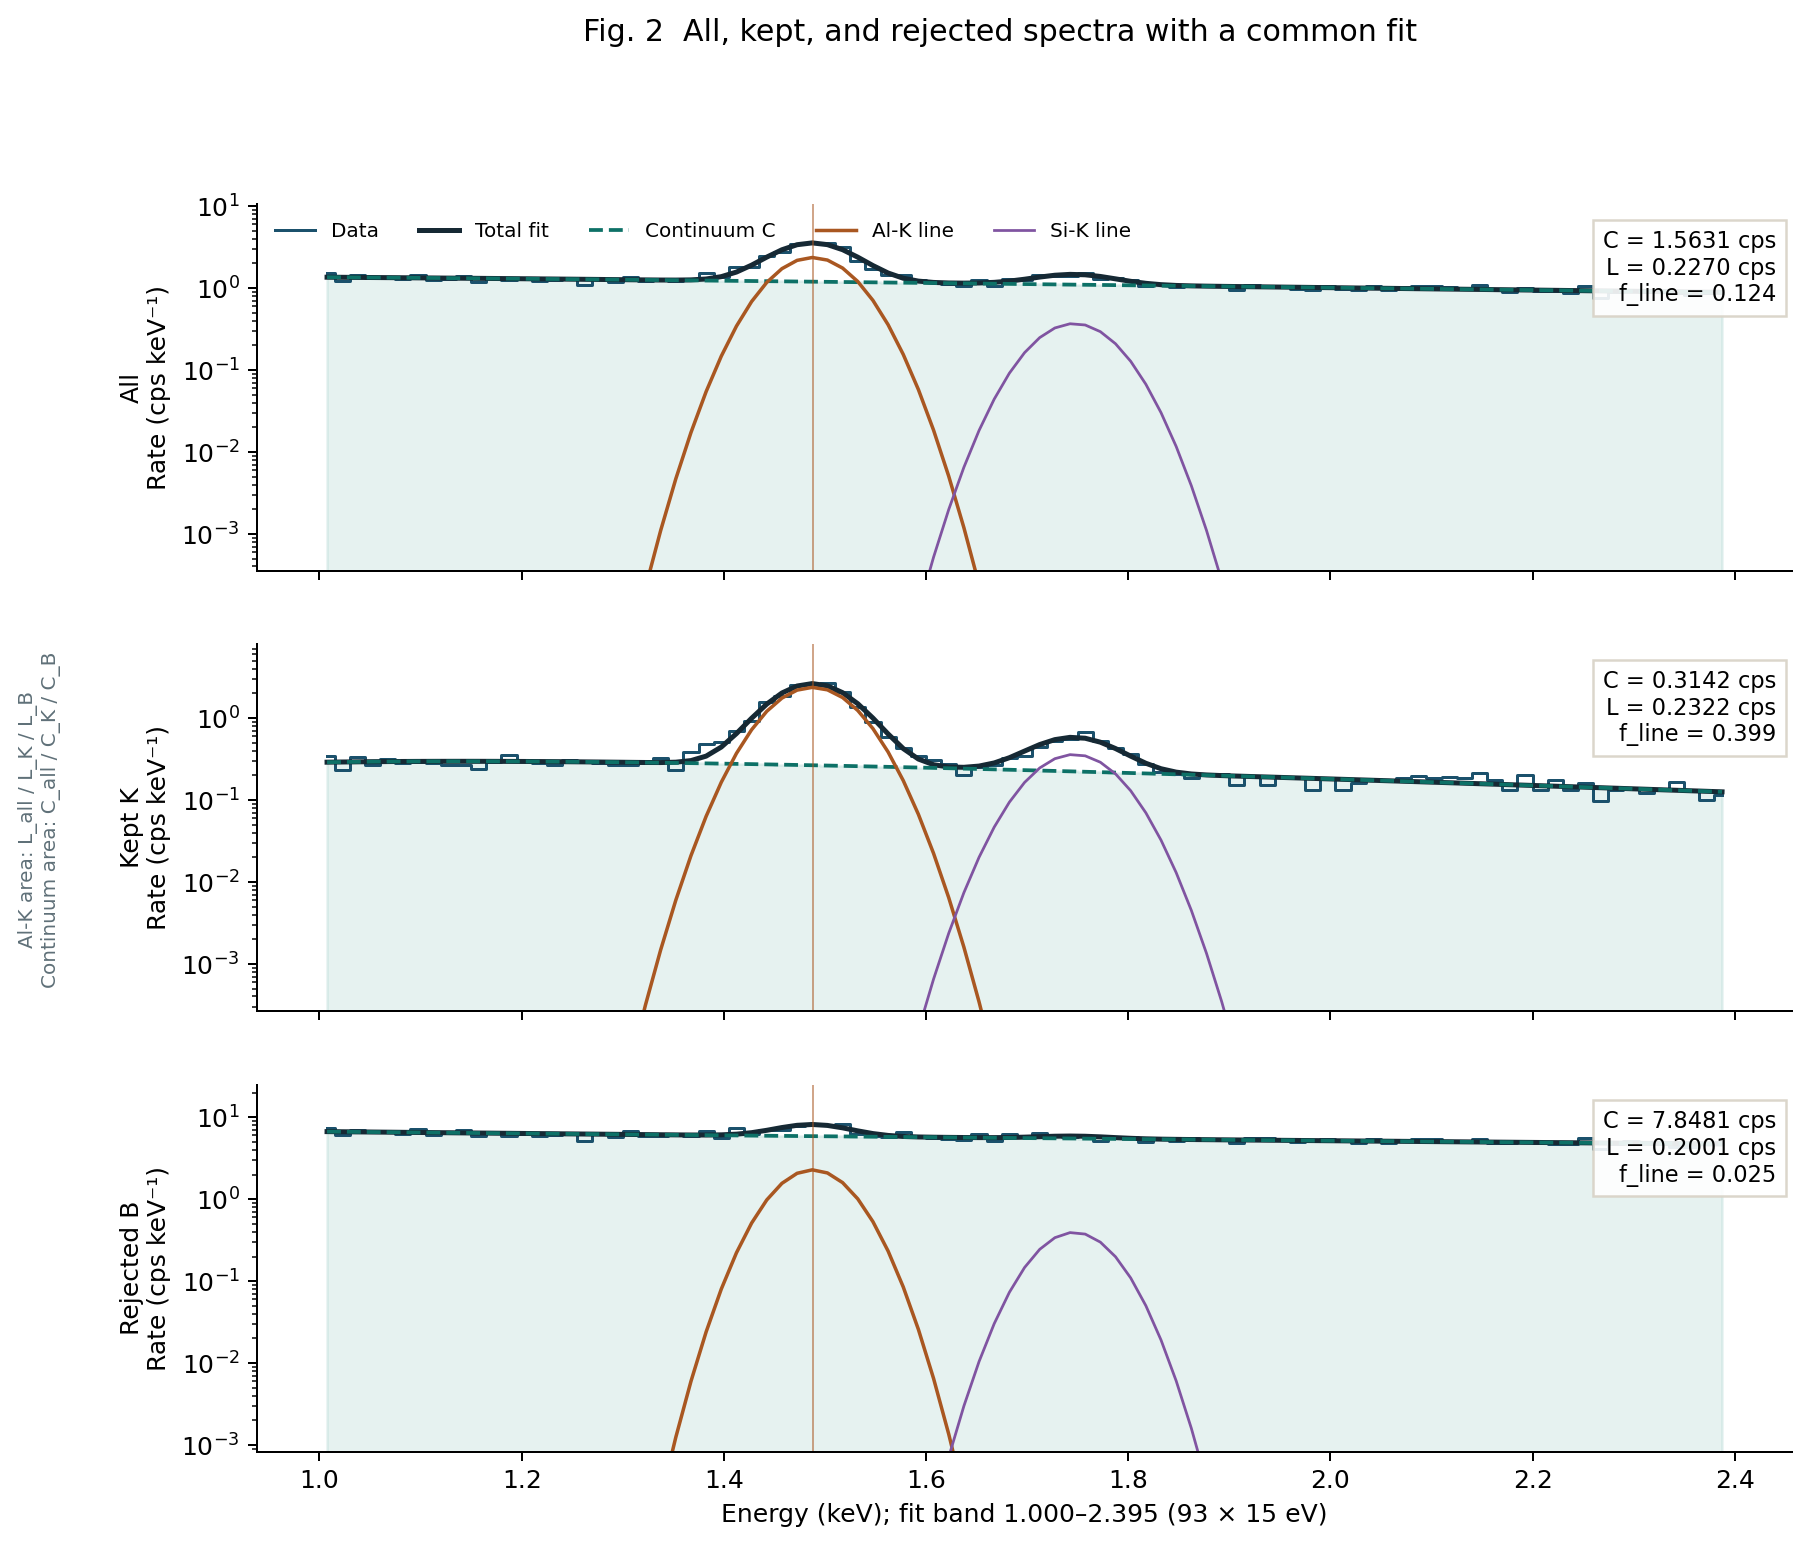
93 个 15 eV bin;Al-K=1.4879、Si-K=1.7466 keV。93 15 eV bins; Al-K=1.4879, Si-K=1.7466 keV.
\(f_T=T_K/T_\mathrm{all}\) 与 \(R\),禁止跨观测平均或排名。\(f_T=T_K/T_\mathrm{all}\) and \(R\); averaging or ranking across observations is forbidden.
Part 1 · anatomyPart 1 · anatomy
1. 先把一个观测拆成 all、kept 与 rejected1. First split one observation into all, kept, and rejected
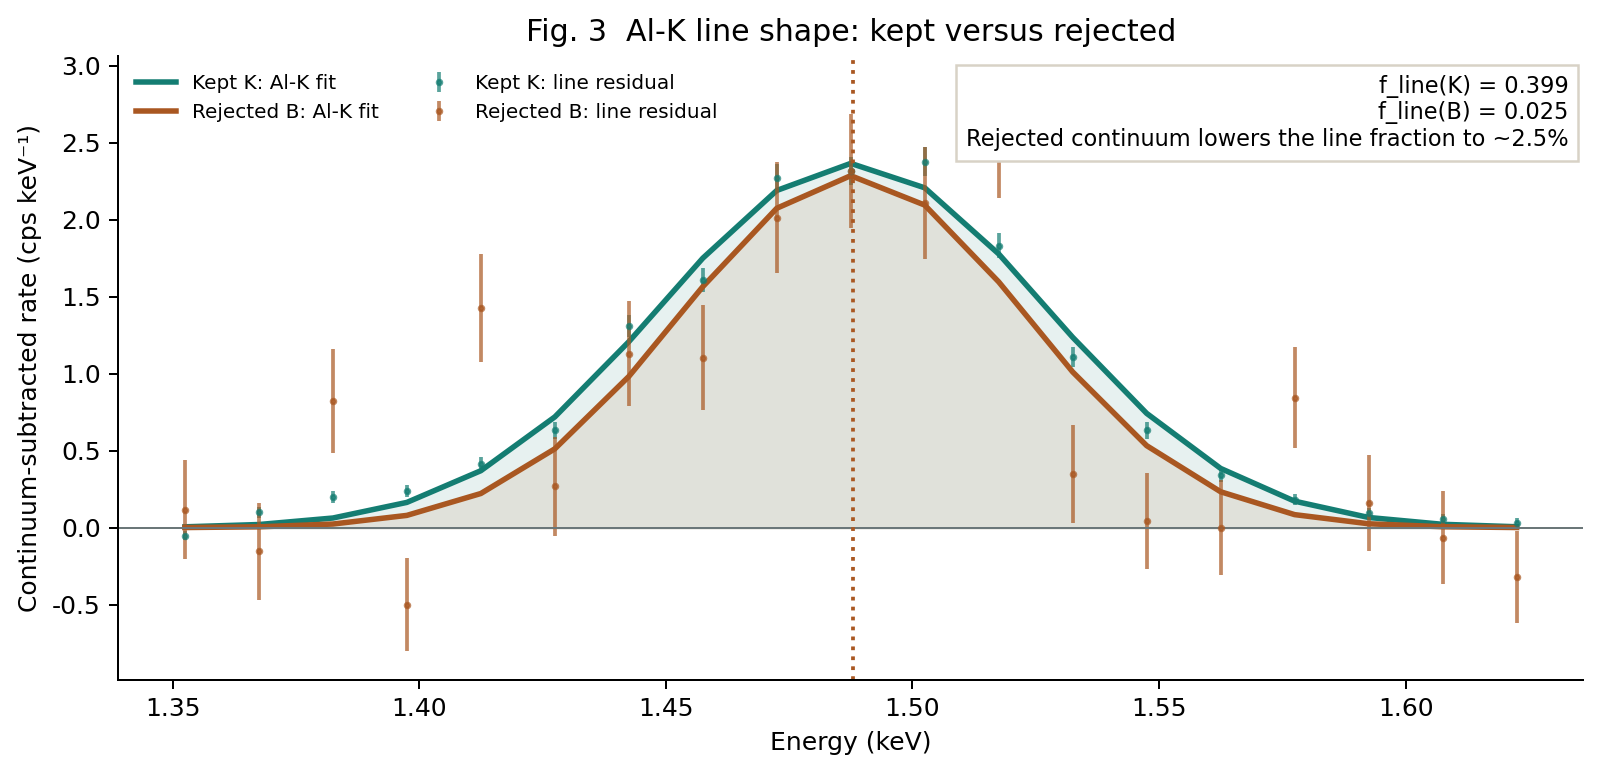
下面四张图固定使用强耀发观测 0800731101 MOS2。每个 100 s cell 的活时间来自 TIMEDEL × FRACEXP 的逐片求和;含事件不等于拥有整整 100 s。The next four figures use the strong-flare observation 0800731101 MOS2. Each 100 s cell gets its live time from the segment-by-segment sum of TIMEDEL × FRACEXP; containing events does not imply a full 100 s.
Part 2 · constraintPart 2 · constraint
2. 让 R 有意义的线,也是防止刷分的锁2. The line that makes R meaningful also blocks score gaming
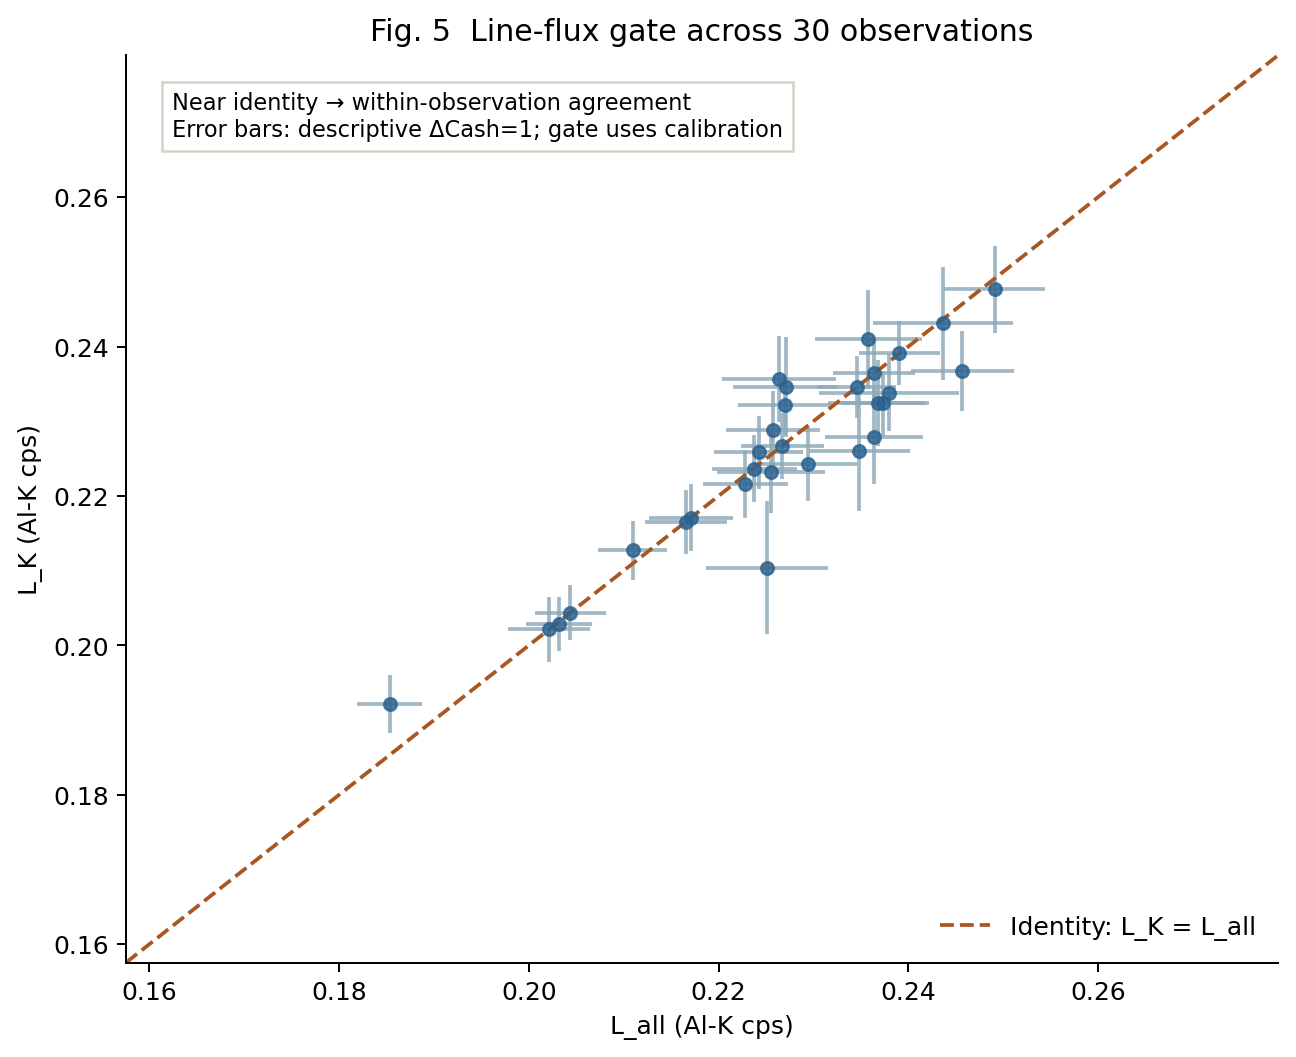
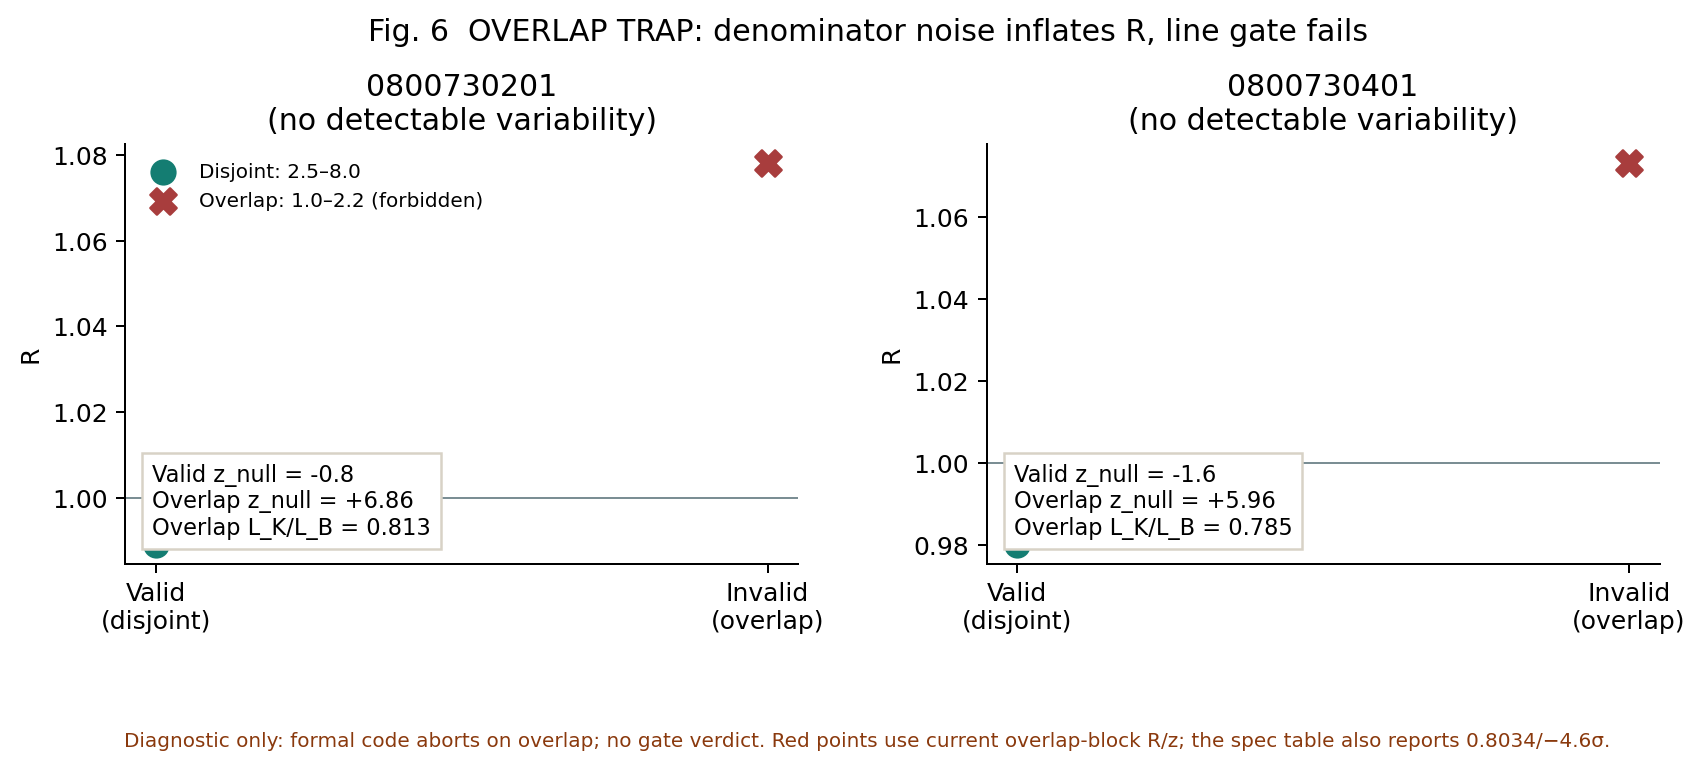
只有在线流量守恒闸门成立时,最大化 \(R\) 才等价于“在保住全时段 Al-K 的同时压低连续谱”。由于 \(L_K-L_\mathrm{all}=(1-f_T)(L_K-L_B)\),切得越多,门既更需要检验,检验力也同步增加。Maximizing \(R\) means lowering the continuum while preserving the all-interval Al-K line only when the line-flux conservation gate holds. Since \(L_K-L_\mathrm{all}=(1-f_T)(L_K-L_B)\), more aggressive cuts make the gate more necessary and increase its testing power at the same time.
措辞边界Wording boundary
“无可探测变率”不等于“无软质子”:0800730201 仍有少量短暂的聚焦软质子签名,且稳态软质子按构造留在 \(C_\mathrm{all}\) 与 \(C_K\) 中,\(R\) 看不见它。“No detectable variability” does not mean “no soft protons”: 0800730201 still has a small transient focused soft-proton signature, while steady soft protons remain by construction in \(C_\mathrm{all}\) and \(C_K\), invisible to \(R\).
Part 3 · frontierPart 3 · frontier
3. 曲线不是前沿:必须让策略结构不同3. A curve is not a frontier: strategy structure must differ
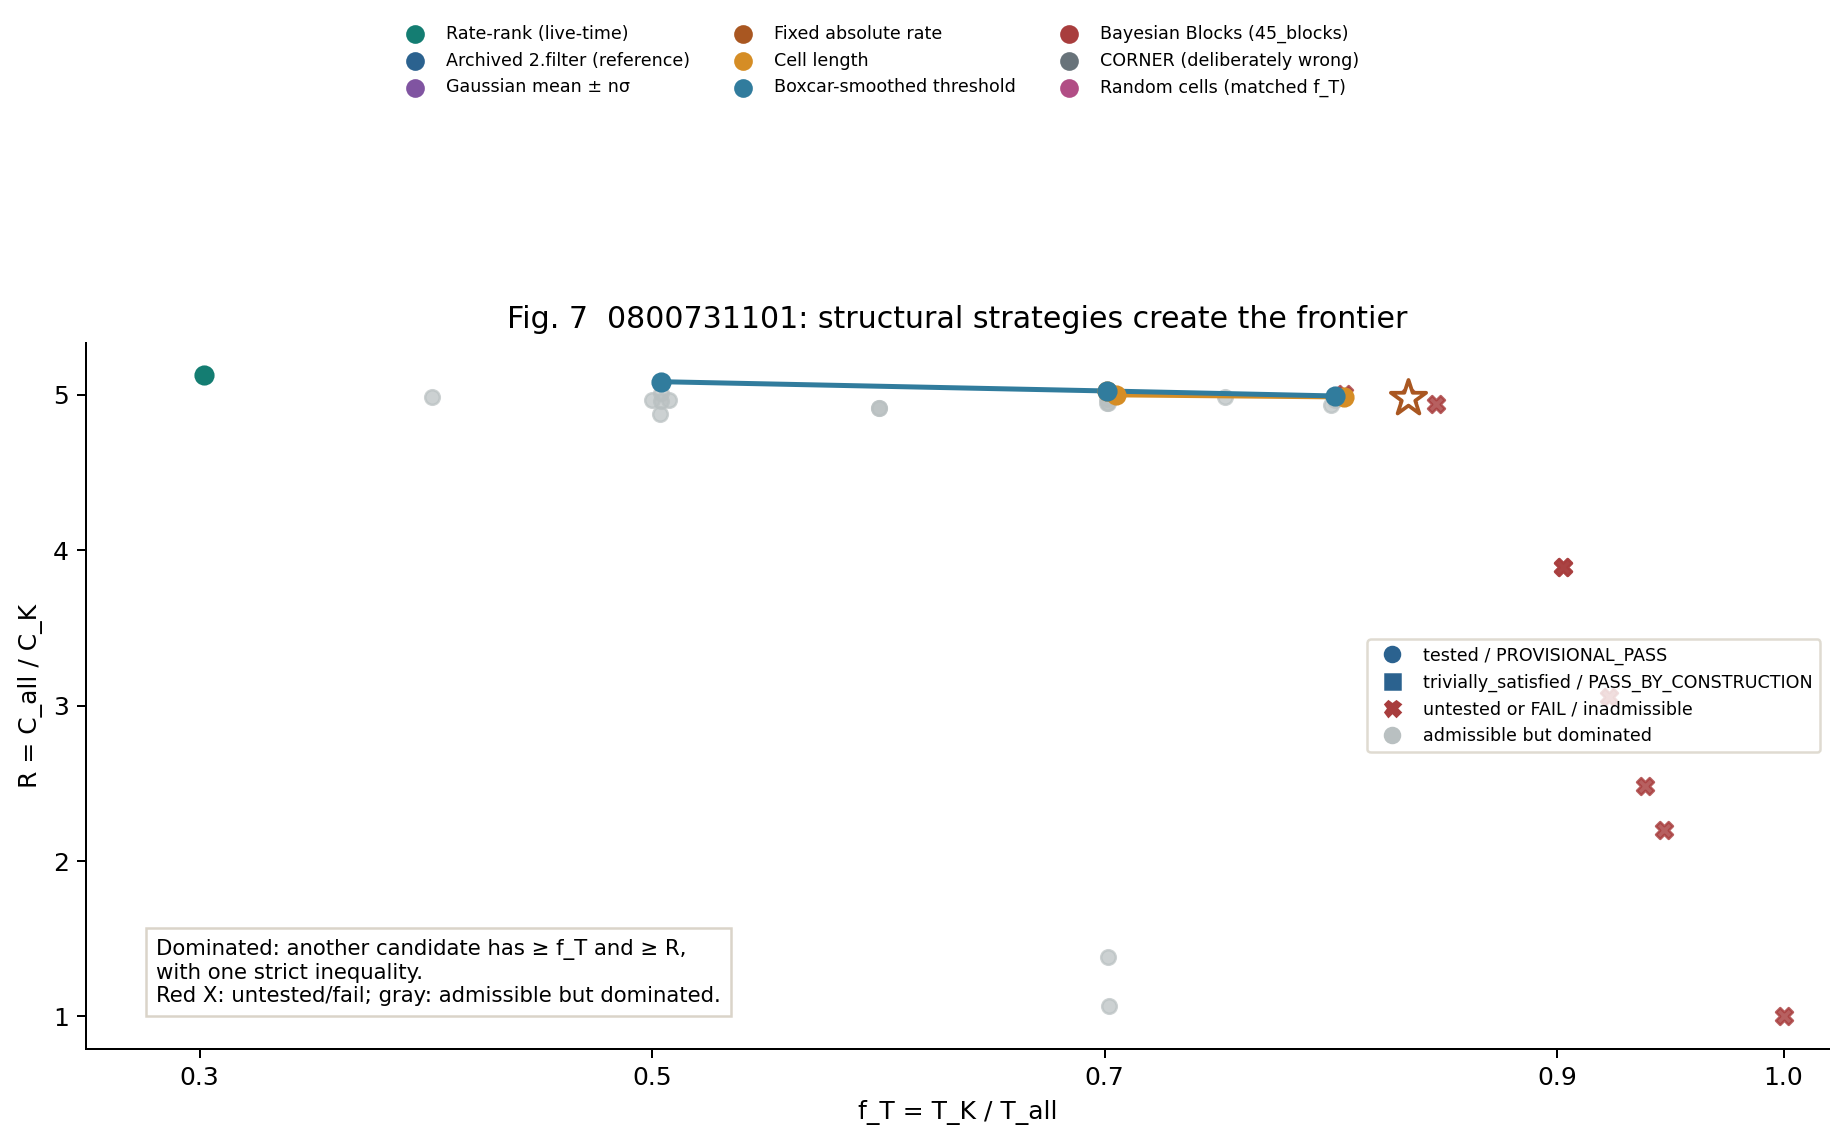
同一 rate-rank 规则只改变 retained fraction,通常得到一条单调曲线,未必有任何点被支配。于是本页在 0800731101 上实际构造了 33 个候选(其中 25 个是新增结构化候选),加入不同 cell 长度、平滑、直方图 cut、固定率阈值、Bayesian Blocks、CORNER 和随机基准;每个候选都重新拟合 K/B,并带 gate class 与 verdict。Changing only the retained fraction under one rate-rank rule usually produces a monotone curve, with no necessarily dominated point. This page therefore constructs 33 candidates on 0800731101 (25 new structured candidates), adding cell lengths, smoothing, histogram cuts, fixed-rate thresholds, Bayesian Blocks, CORNER, and a random baseline; every candidate refits K/B and carries a gate class and verdict.
| 策略族Strategy family | 候选数Count | 定义Definition |
|---|---|---|
| rate-rank(真实活时间)rate-rank (measured live time) | 8 | \(f_T=0.30,\ldots,1.00\);现有规则。\(f_T=0.30,\ldots,1.00\); existing rule. |
| 归档 2.filter(参考)Archived 2.filter (reference) | 1 | 图中星号;不是新策略族。Star in the figure; not a new strategy family. |
| 高斯均值 ± nσGaussian mean ± nσ | 3 | \(n=1.5,2,3\),保留 histogram 的均值±nσ 内 cells。\(n=1.5,2,3\); keep cells within the histogram mean ± nσ. |
| 固定绝对率阈值Fixed absolute-rate threshold | 3 | 阈值由本观测实际率分位数得到,不跨观测移植。Thresholds come from this observation's measured-rate quantiles and are not transferred across observations. |
| 不同 cell 长度Different cell lengths | 9 | 50/200/500 s,各取 \(f_T=0.5,0.7,0.8\)。50/200/500 s, each at \(f_T=0.5,0.7,0.8\). |
| boxcar 平滑后阈值Boxcar-smoothed threshold | 6 | 5/11 个原始 100 s cells 平滑,各取三个目标份额。Smooth 5/11 original 100 s cells, each at three target fractions. |
| Bayesian BlocksBayesian Blocks | 1 | 事件时间的 45 blocks,按 block 率保留到约 0.70。45 event-time blocks, retaining about 0.70 by block rate. |
| CORNER 选择(故意错误)CORNER selection (deliberately wrong) | 1 | 以角落曲线排序;只用于展示错误方向。Rank by the corner curve; used only to show the wrong direction. |
| 随机 cells(匹配 \(f_T\))Random cells (matched \(f_T\)) | 1 | 随机率排序到约 0.70;作为 dominated lower bound。Random-rate ranking to about 0.70; a dominated lower bound. |
| 候选Candidate | \(f_T\) | \(T_K\) (ks) | \(R\) | gate class / verdictgate class / verdict |
|---|---|---|---|---|
| rate-rank 0.30rate-rank 0.30 | 0.3021 | 7.399 | 5.126 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
| cell 200 s, 0.70cell 200 s, 0.70 | 0.7011 | 17.173 | 5.024 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
| cell 200 s, 0.80cell 200 s, 0.80 | 0.8059 | 19.739 | 4.985 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
| cell 500 s, 0.70cell 500 s, 0.70 | 0.7052 | 17.273 | 4.998 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
| smooth 11 cells, 0.50smooth 11 cells, 0.50 | 0.5038 | 12.341 | 5.083 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
| smooth 11 cells, 0.70smooth 11 cells, 0.70 | 0.7012 | 17.175 | 5.023 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
| smooth 11 cells, 0.80smooth 11 cells, 0.80 | 0.8020 | 19.644 | 4.991 | tested / PROVISIONAL_PASStested / PROVISIONAL_PASS |
故意的 CORNER 策略(\(f_T=0.7014,R=1.383\))与随机匹配策略(\(f_T=0.7017,R=1.066\))都落在前沿以下,符合预期;它们没有被隐藏,反而作为错误选择与噪声下界保留在灰点中。The deliberately wrong CORNER strategy (\(f_T=0.7014,R=1.383\)) and the random matched strategy (\(f_T=0.7017,R=1.066\)) both lie below the frontier, as expected. They remain visible as wrong-choice and noise-floor gray points.
Part 4 · boundariesPart 4 · boundaries
4. 边界要写在结论旁边4. Put the boundaries beside the conclusions
R 不能跨观测比较R is not comparable across observations
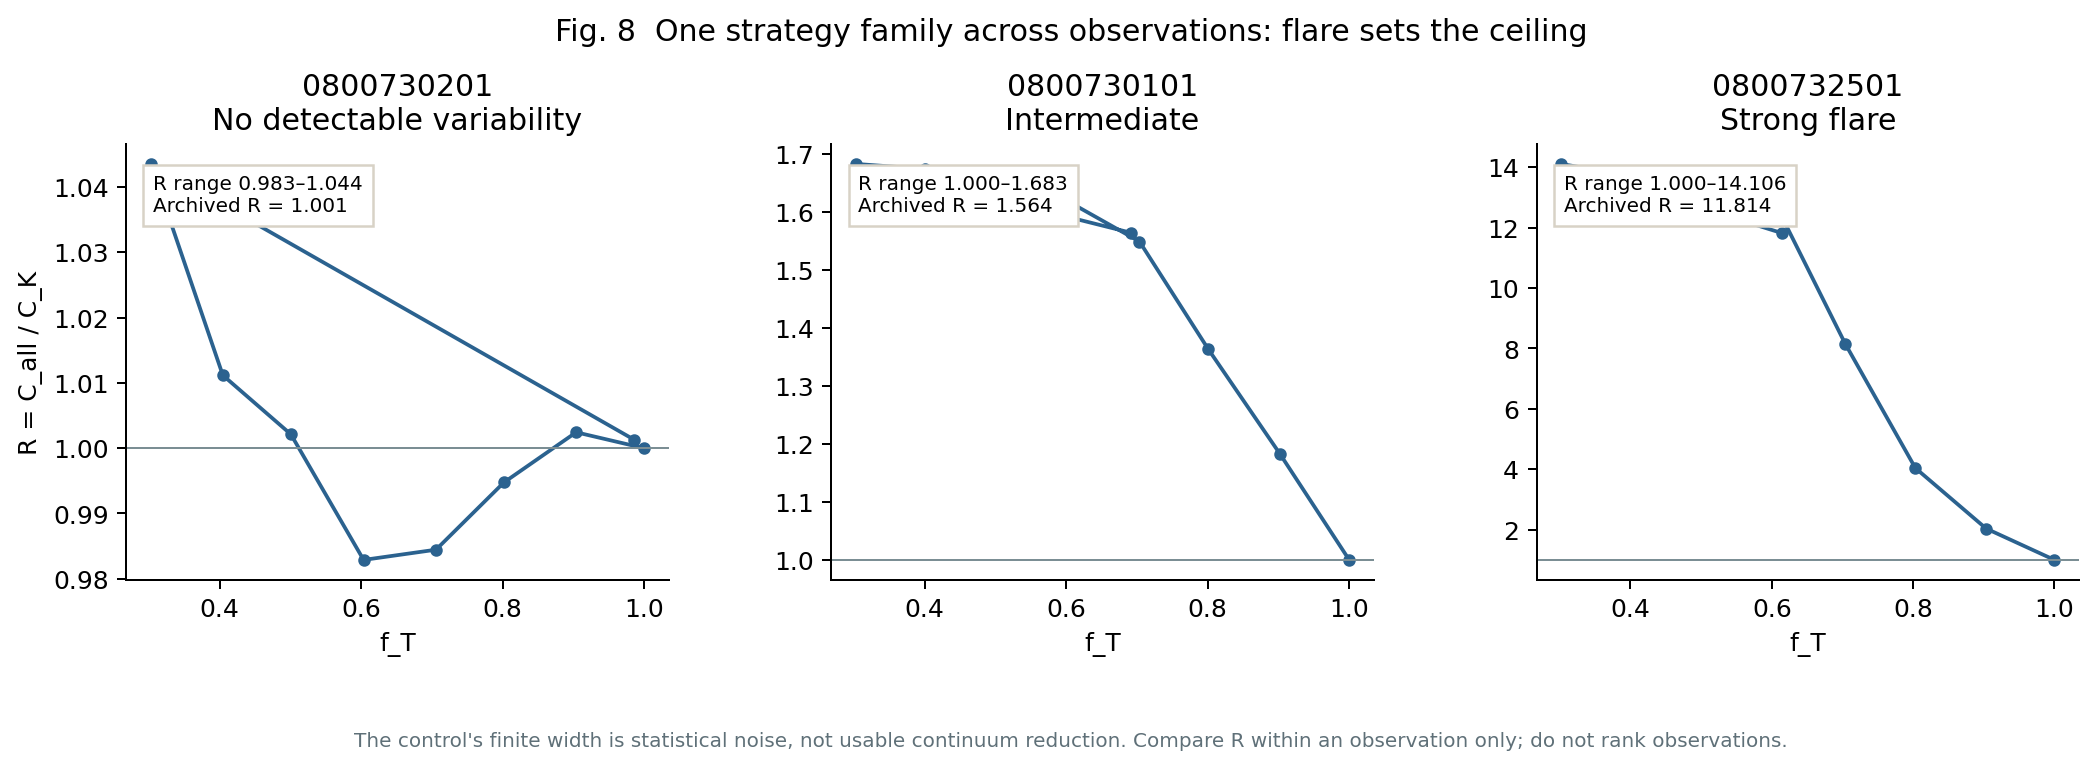
\(R\) 的 ceiling 由观测自身 flare 强度设置,而不是由策略好坏设置。因此 \(R\) 绝不能跨观测平均、排名或 pooled;前沿按观测分别绘制,只比较它们的形状。它不是软质子去除比例。The ceiling of \(R\) is set by how flared the observation happens to be, not by how good the strategy is. Therefore \(R\) must never be averaged, ranked, or pooled across observations; frontiers are drawn per observation and only their shapes compare. It is not a soft-proton removal fraction.
稳态 soft proton 不可见Steady soft protons are invisible
稳定成分同时抬高 all 与 kept 的连续谱,\(R\) 仍可接近 1;因此本框架不测 absolute SP count。A steady component raises the all and kept continua together, so \(R\) can remain near 1; this framework therefore does not measure absolute SP counts.
异常 CCD / 紧致变源不由 R 分辨R does not resolve bad CCDs or compact variables
故障注入 receipt 显示:它们可使 \(R\) 达到约 4σ,而 gate 仍在 0 附近。需独立的 CCD 与空间筛查。Fault-injection receipts show that they can drive \(R\) to about 4σ while the gate remains near 0. Independent CCD and spatial screening is required.
门 verdict 目前是 provisionalThe gate verdict is provisional
实现记录 \(s=-0.01284\pm0.00394\) 的线—连续谱耦合及每个候选的 \(s\lambda\),但按冻结裁决不施加改正。The implementation records line–continuum coupling \(s=-0.01284\pm0.00394\) and \(s\lambda\) for every candidate, but the frozen adjudication does not apply the correction.
两个仍然开放的问题Two questions remain open
- 线—连续谱耦合改正的方向与大小最终应如何施加?现有受控注入给出负斜率,但改正后全样本仍出现约 −2.2 至 −2.5σ 的线亏损,可能意味着 Al-K 随粒子通量变化,也可能是第二个未建模系统。How should the direction and size of the line–continuum coupling correction ultimately be applied? Controlled injections give a negative slope, but the corrected full sample still shows about −2.2 to −2.5σ line loss, which could mean Al-K changes with particle flux or could indicate a second unmodeled system.
- Al-K 在线性平均意义上稳定,不等于它在一次观测内没有慢时间结构;需要用角落粒子率作为独立探针继续检验。Al-K being stable in a linear-average sense does not mean that one observation lacks slow temporal structure; corner-particle rate must be tested as an independent probe.
带走的三句话Three takeaways
第一,\(R\) 只有在同一观测内才是固定参照下的坐标。第二,线既定义了“连续谱降低”的守门条件,也防止率选择把噪声当成收益。第三,前沿必须由结构不同的策略产生,且每个点都要携带 gate class 与 verdict。First, \(R\) is a fixed-reference coordinate only within one observation. Second, the line both defines the gate for continuum reduction and prevents rate selection from turning noise into gain. Third, the frontier must come from structurally different strategies, and every point must carry a gate class and verdict.